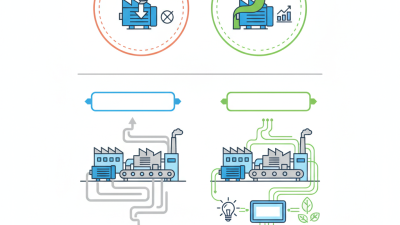
Choosing the right motors and controls starts with the work the machine must do, not the catalog page. A conveyor carrying uneven loads needs different behavior from a fan running at steady speed. Record the required speed, torque, duty cycle, starting frequency, and operating environment. A motor that looks adequate on paper may overheat during repeated starts. Small details matter.
Austin Hughes, co-author of Electric Motors and Drives, explains the importance of considering the motor and drive together. A concise paraphrase of that principle is: “Choose the motor and its control as one system.” This is more than a purchasing tip. The control must support the motor’s voltage, current, speed range, and starting needs. It should also provide useful protection and fit the application’s operating conditions. A variable-speed drive can improve process control, but it is not automatically the best choice for every installation.
Then compare efficiency, maintenance needs, installation space, and total operating cost. Check the manufacturer’s ratings and wiring guidance, and have qualified personnel verify the selection before commissioning. Measure twice. Real loads can surprise you, and an early estimate may be wrong. That is worth admitting. A practical selection process leaves room to revisit assumptions after testing, especially when noise, heat, or vibration differs from expectations. The right motors and controls should perform reliably under actual conditions—not just match a specification sheet.
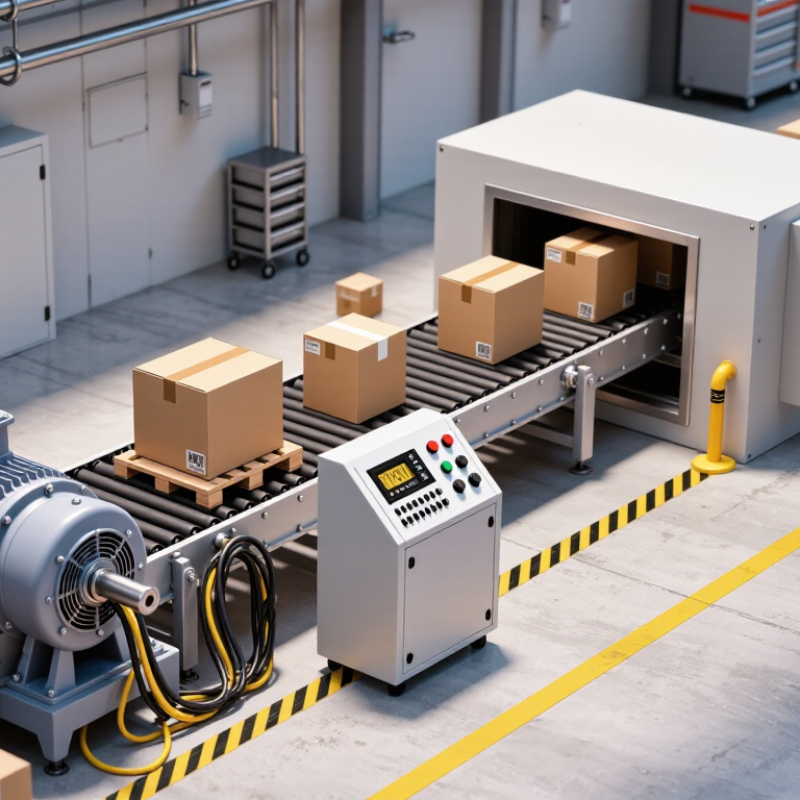
Choosing a motor starts with the task, not the catalog. Describe what the machine must move, how far, how fast, and how often. A conveyor carrying cartons needs steady torque; a pick-and-place arm may need rapid starts, precise stops, and repeated reversals. Record the load’s weight, travel distance, target speed, acceleration, and operating hours. Small details matter.
The International Energy Agency’s 2011 report, Energy-Efficiency Policy Opportunities for Electric Motor-Driven Systems, estimates that these systems use about 45% of global electricity. That figure is broad, but it shows why matching a drive to its real duty matters.
Specify the full motion profile, including peak load, normal load, starts per hour, and required stopping accuracy. A motor selected only for peak torque may be unnecessarily large. That estimate can mislead. Check load inertia and expected heat buildup, too; a unit that performs well during one test may struggle through a long production shift. Then choose controls that support the needed speed range, feedback, and braking behavior. If the load or cycle is uncertain, measure it before committing. Guessing is tempting, but it can hide the actual requirement.
Motor choice begins with the load, not the nameplate alone. Record required torque, speed range, starts per hour, and duty cycle. The IEA’s 2011 report, Energy-Efficiency Policy Opportunities for Electric Motor-Driven Systems, estimates these systems use about 45% of global electricity. Small efficiency differences matter across long operating hours.
Induction motors are rugged and widely used for pumps, fans, and conveyors. Their speed can be controlled with a variable-frequency drive, though low-speed cooling and drive losses deserve attention. Synchronous motors hold speed closely and can offer strong efficiency, but usually need more specialized control. Brushed DC motors provide straightforward speed adjustment; brushes add wear and maintenance. Permanent-magnet motors can deliver high torque in a compact frame, yet magnet cost and service requirements may complicate a retrofit. There is no universal winner. A pump running steadily differs from a hoist facing repeated starts.
Tips: Compare efficiency at the actual operating point, not only at rated load. Check starting torque, enclosure, cooling, and controller compatibility. Ask for test data under your duty cycle. A catalog figure may not match the machine on your floor.
Measure the load. Motor selection should begin with required torque across the full operating cycle, not just the machine’s peak horsepower. A conveyor may need high starting torque when fully loaded, while a fan usually needs less torque at startup. Check speed under load, acceleration time, and any gearbox ratio. The U.S. Department of Energy’s 2014 report, Improving Motor and Drive System Performance, attributes about 64% of U.S. industrial electricity use to motor-driven systems. That scale makes careful matching worthwhile.
Duty cycle matters just as much. Record operating hours, starts per hour, idle periods, and ambient temperature; these affect motor heating and service life. A variable-frequency drive can adjust speed, but it does not fix every mismatch. At low speeds, a self-cooled motor may lose cooling airflow, so verify its thermal limits. Not a small detail. Allow margin for real load variation, but avoid oversizing by habit: oversized motors can run inefficiently under light loads. Calculations are only a starting point. Compare the selected motor and controls with measured current, torque, and temperature during commissioning, then revisit assumptions if the machine behaves differently than expected.
| Application | Typical Load Characteristics | Example Motor Selection | Rated Speed | Approx. Rated Motor Torque | Typical Duty | Control and Selection Considerations |
|---|---|---|---|---|---|---|
| Small belt conveyor | Steady load; starting torque depends on belt tension and conveyed material. | 0.55 kW, 4-pole AC induction motor with gearbox | About 1,450 rpm motor speed at 50 Hz | About 3.6 N·m at the motor shaft | S1, continuous operation | Use a variable-frequency drive (VFD) when adjustable speed or soft starting is needed. Size the gearbox for required output speed and torque. |
| Industrial mixer | Variable load with potentially high breakaway torque, especially with viscous material. | 1.5 kW, 4-pole AC induction motor with suitable gearbox | About 1,450 rpm motor speed at 50 Hz | About 9.9 N·m at the motor shaft | S1, continuous operation | A vector-control VFD can provide improved low-speed torque. Check starting torque, gearbox rating, and the mixer’s worst-case material load. |
| Centrifugal pump | Torque generally rises with speed; starting load is often moderate when the system is correctly configured. | 2.2 kW, 4-pole AC induction motor | About 1,450 rpm at 50 Hz | About 14.5 N·m | S1, continuous operation | A VFD may regulate flow and reduce starting current. Confirm pump power demand across the operating range and protect against dry running where required. |
| Ventilation fan | Fan power demand typically increases substantially as speed rises. | 4.0 kW, 4-pole AC induction motor | About 1,450 rpm at 50 Hz | About 26.3 N·m | S1, continuous operation | A VFD can provide speed control. Check the fan curve, system resistance, and motor cooling at reduced speeds. |
| Packaging-machine indexing axis | Repeated acceleration, deceleration, and accurate positioning. | 0.75 kW AC servo motor with matching servo drive | About 3,000 rpm rated speed | About 2.4 N·m rated torque | Intermittent cyclic duty; assess using the actual motion profile | Check peak torque, RMS torque, inertia ratio, positioning accuracy, and cycle time. The drive and feedback device must be compatible with the motor. |
| Industrial hoist | High starting and holding requirements; load torque can vary with payload and direction. | 3.0 kW, hoist-rated brake motor with suitable drive | About 1,450 rpm motor speed at 50 Hz | About 19.8 N·m at the motor shaft | Intermittent duty; determine the required duty class from starts, load, and operating time | Use a properly rated mechanical brake and a drive configured for lifting applications. Verify load capacity, braking, thermal duty, and applicable safety requirements. |
Note: These are illustrative examples, not final equipment specifications. Approximate motor-shaft torque is calculated as 9,550 × power (kW) ÷ speed (rpm). For geared systems, output torque depends on gear ratio and efficiency. Final selection should use the actual load profile, acceleration, service conditions, supply, and required safety margins.
Choosing a motor is only half the task. The drive must match its voltage, continuous current, and peak current ratings. A drive that barely covers peak demand may trip during acceleration or sudden load changes. Leave margin. Confirm that the controller supports the drive’s command method, such as step-and-direction, analog signals, or a network interface. Check update rates and required interlocks before wiring.
Feedback must also be compatible across the motor, drive, and controller. An incremental encoder needs the right input type and resolution; an absolute encoder may require a specific communication protocol. Read the pinout carefully, and keep feedback cables away from motor power wiring to reduce electrical noise. I would not treat a datasheet match as proof of a good system: cable routing and load inertia can still cause surprises. Bench-test the setup at low speed, then check position error, temperature, and stopping behavior under a representative load.
Select compatible drives, controllers, and feedback.
This illustrative 48 V servo example shows a motor rated for 6 A continuous and 18 A peak paired with a drive rated for 8 A continuous and 20 A peak. Confirm that the drive’s voltage range and current ratings meet the motor requirements, then verify feedback-device compatibility and that the drive supports the controller’s command interface.
Verify Power, Safety, Environment, and System Integration
Start with the machine’s real load, not just its nameplate estimate. A conveyor carrying uneven boxes may need extra torque during startup. Check supply voltage, phase, peak current, speed range, and operating hours. The control method should match the job: variable speed requires suitable drive capacity and motor compatibility. Leave room for brief overloads, but avoid oversizing without a reason. Bigger is not automatically better.
Safety needs practical checks. Confirm that guards, emergency stops, overload protection, and restart behavior work together. A machine should not resume unexpectedly after power returns. Test it. Consider where the equipment will run. Fine dust, washdown, vibration, and high temperatures can shorten component life or affect cooling. Select enclosures and materials for those conditions, then check the installation details. A rating on paper cannot fix a poorly sealed cable entry.
Integration is often where a sound selection gets messy. Verify control signals, feedback devices, wiring distances, and communication with the wider system before ordering. If a controller expects one signal type and receives another, commissioning slows down. Still, the first estimate is rarely perfect. Run a realistic test under load, record current and temperature, and adjust settings carefully. Small details matter.