What Are the Top Variable Frequency Drive Types in 2026?

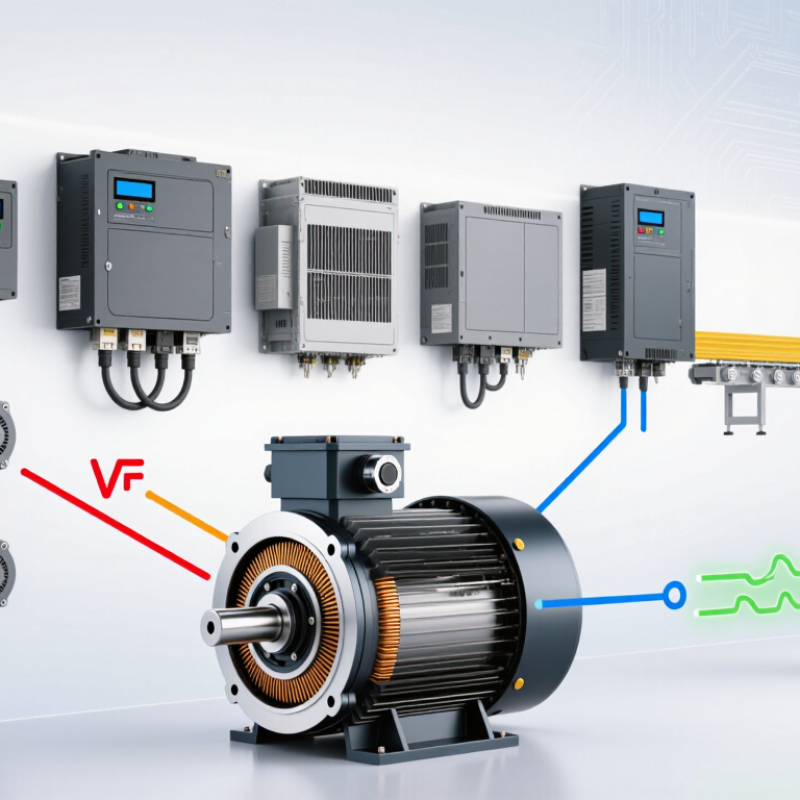
In 2026, choosing a variable frequency drive means matching its design to the motor, load, and installation. The best fit depends on required speed control, torque, power rating, and operating conditions. A water pump may run for long periods at changing flow rates. A loaded conveyor may need strong starting torque and controlled acceleration. Details matter. A well-selected drive can improve process control and reduce mechanical stress. Energy savings are possible, but not automatic; they depend on the load profile, system design, and hours of operation.

This overview examines common drive types, including voltage-source inverter and current-source inverter designs, low- and medium-voltage models, and regenerative drives that can return braking energy to a compatible system. It also clarifies an easily missed distinction: V/f, sensorless vector, and closed-loop vector describe control methods, not separate power-conversion topologies. Each approach has trade-offs in cost, motor response, complexity, and suitability for particular applications. Not every feature is useful on every site. Before comparing products, check motor compatibility, supply voltage, enclosure rating, cooling needs, and harmonic requirements. The aim is not to name one universal winner, but to help readers identify which variable frequency drive type deserves closer evaluation for their equipment. A specification sheet helps, but actual commissioning conditions can still change the decision.
What Are the Top Variable Frequency Drive Types in 2026?

VFD Basics: Synchronous Speed Follows n = 120f/p (rpm)

A variable frequency drive changes the electrical frequency supplied to a motor, giving operators a practical way to control rotational speed. The basic relationship is n = 120f/p, where n is synchronous speed in revolutions per minute, f is frequency in hertz, and p is the number of motor poles. The equation describes the speed of the rotating magnetic field inside the motor.

Numbers make it clear. At 60 Hz, a four-pole motor has a synchronous speed of 1,800 rpm. At 50 Hz, the same pole count gives 1,500 rpm. A VFD can adjust frequency to move this field speed up or down. For example, reducing frequency to 30 Hz gives a four-pole motor a synchronous speed of 900 rpm.

That is not always the shaft speed. In an induction motor, load creates slip, so the rotor typically turns somewhat slower than the calculated field speed. Treating the formula as an exact shaft-speed reading can mislead. Check the motor’s rated voltage and frequency, and consider cooling and torque needs when changing speed. At very low speeds, a standard motor’s fan may move too little air. The formula is simple; applying it well takes context.

PWM Voltage-Source Drives: 2-Level and 3-Level Topologies

PWM voltage-source drives shape motor voltage by rapidly switching a DC bus. In a 2-level topology, each phase switches between two voltage states. The resulting pulses approximate a sine wave as motor inductance smooths the current. Simple power stages and mature controls make this topology common in pumps, fans, and general-purpose machinery. Yet fast voltage changes can stress motor insulation, especially with long cables. Output filters may help, but they add cost and require careful sizing.

A 3-level drive adds a zero-voltage state, creating smaller voltage steps at the motor terminals. Neutral-point-clamped and T-type circuits are common approaches, though their component arrangements differ. Smaller steps can reduce harmonic distortion and voltage rise time, which may ease stress on cables and insulation. That helps. The trade-off is more complex switching, protection, and DC-link voltage balancing. Engineers should check load speed range, cable length, motor insulation, and expected duty cycle before choosing. In practice, the 3-level waveform can look cleaner on an oscilloscope, but that alone does not guarantee lower system cost or better reliability. The installation details still matter.

What Are the Top Variable Frequency Drive Types in 2026?

PWM Voltage-Source Drives: 2-Level and 3-Level Topologies

The chart compares the available voltage levels at one inverter phase leg. A 2-level topology switches between two levels, while a 3-level topology provides three. For the same DC-link voltage, the 3-level arrangement adds a zero level and produces smaller voltage steps.

Current-Source and Load-Commutated Drives for Motors Above 1 kV

What Are the Top Variable Frequency Drive Types in 2026?
Current-Source and Load-Commutated Drives for Motors Above 1 kV

For motors above 1 kV, current-source drives deserve attention when power levels are high and operating conditions are demanding. They regulate motor current through a DC link, typically using a large inductor. This design can provide controlled operation for heavy industrial loads. A load-commutated inverter, or LCI, is a current-source drive that uses a synchronous motor’s back electromotive force to switch current. It often suits large compressors, pumps, and mills. The neat diagrams can mislead: starting and low-speed operation need careful consideration.

Selection depends on the motor, load profile, and site requirements—not voltage alone. An LCI may require starting equipment because the motor cannot provide effective commutation at very low speed. Engineers should also assess harmonics, reactive power, cooling, and motor insulation. A wrong assumption about duty cycle can become costly. I would verify the actual speed range and load torque before comparing drive types, then confirm compatibility with the motor manufacturer’s data. Not every high-power application needs an LCI.

Tips: Check the motor’s starting method, minimum operating speed, and harmonic limits early. Ask for measured load data, not just the nameplate rating. During commissioning, record current and temperature at key operating points.

What Are the Top Variable Frequency Drive Types in 2026? — Current-Source and Load-Commutated Drives for Motors Above 1 kV
Drive type DC-link and switching principle Typical motor and voltage fit Main strengths Key considerations Common applications
Load-Commutated Inverter (LCI) Thyristor-based current-source system. The motor’s back EMF helps commutate the inverter thyristors; the DC link includes a smoothing reactor. Primarily large synchronous motors in medium-voltage systems above 1 kV, commonly used at multi-megawatt power levels. Well suited to very high power; robust thyristor technology; can provide efficient, controllable operation for large synchronous motor loads. Requires a suitable synchronous motor and excitation system. Commutation depends on motor back EMF, so low-speed operation and starting require careful system design. Large compressors, pumps, fans, mills, and other high-power industrial process drives.
Self-Commutated Current-Source Inverter (CSI) A DC-link inductor maintains a relatively smooth DC current. Inverter switches control the current supplied to the motor; commutation is handled by the power-electronic circuit rather than relying solely on motor back EMF. Medium-voltage motor systems above 1 kV. The specific motor compatibility and usable power range depend on the converter topology and switching devices. Current-source operation can provide inherent current limiting and a robust DC link. Some implementations support regenerative power flow. Requires a suitable motor and converter design. Filtering, motor insulation coordination, and the drive’s switching and regeneration capabilities should be checked for each application. Industrial pumps, compressors, fans, and process machinery where a current-source topology is specified.
CSI-Based Synchronous-Motor Drive Current-source conversion paired with a synchronous motor; the converter controls motor current and works with the motor excitation system. Above-1-kV systems where a synchronous motor is appropriate, especially in large, steady-duty installations. Can suit high-power installations and allows motor excitation to be considered as part of system power-factor management. Requires coordination among the converter, motor, excitation system, and protection scheme. Confirm starting method, operating-speed range, and reactive-power requirements. Large process loads with a dedicated synchronous motor, including selected compressor and pumping installations.
CSI-Based Induction-Motor Drive Current-source inverter supplies controlled variable-frequency current to an induction motor; the DC-link inductor smooths current. Above-1-kV installations using compatible medium-voltage induction motors; suitability is topology- and rating-dependent. Provides variable-speed control without requiring a synchronous motor or separate rotor excitation system. Check motor compatibility, harmonic performance, torque demands, and whether the selected design supports the required braking or regeneration behavior. Medium-voltage fans, pumps, and other industrial loads requiring adjustable speed.

Note: These are established current-source drive categories, not a performance ranking. Voltage, power, speed range, motor compatibility, and regenerative capability vary by design and application; confirm them against the specific drive and motor specifications.

Control Methods: V/f, Sensorless Vector, and Encoder Feedback

V/f control varies voltage and frequency together to keep motor flux near its target. It suits fans, pumps, and conveyors with gradual load changes. Setup is straightforward, but speed regulation can drift when loads shift. A pump may run smoothly at steady flow, then lag when a valve closes.

Sensorless vector control estimates motor speed from electrical feedback. It usually delivers stronger torque at low speeds without an encoder, making it useful for mixers and loaded conveyors. It does depend on accurate motor data and tuning. Small parameter errors can show up as rough starts or unexpected heating. Not magic.

Encoder feedback measures shaft speed directly, giving tighter control at very low speeds and during rapid changes. It is often chosen for hoists, winders, and positioning tasks, where slip matters. The trade-off is added wiring, commissioning, and maintenance. The U.S. Department of Energy’s 2014 Improving Motor and Drive System Performance sourcebook estimates motor systems use about 54% of U.S. manufacturing electricity. The IEA’s motor-driven-systems analysis estimates roughly 45% of global electricity use. Those figures explain why control choice matters, but they do not identify one best method. Match the drive to the load, speed range, and required accuracy, then verify performance on the actual machine.

Efficiency Checks: IEC 61800-9-2 IE/IES Classes and 50/60 Hz Supplies

What Are the Top Variable Frequency Drive Types in 2026?

Efficiency Checks: IEC 61800-9-2 IE/IES Classes and 50/60 Hz Supplies

Efficiency claims need a clear comparison point. IEC 61800-9-2 assigns IE classes to complete drive modules and IES classes to power drive systems. These ratings compare losses against defined reference values; they are not interchangeable with a motor’s efficiency label. Check the class, operating point, and test conditions before comparing equipment. Small details matter.

The International Energy Agency’s report Energy-Efficiency Policy Opportunities for Electric Motor-Driven Systems estimates these systems use about 45% of global electricity. That figure covers motor-driven applications broadly, including pumps and fans—not variable frequency drives alone. In a plant, record actual load and operating hours. A drive running a lightly loaded pump may save less than its peak-efficiency figure suggests.

For 50/60 Hz supplies, verify the drive’s rated input voltage and frequency against the site supply. A drive may accept both frequencies, but voltage limits, current, and derating still need checking against its technical documentation. Then assess system losses across realistic speeds and loads, not just one test point. It is easy to overlook the motor and cable. That can make an otherwise careful IE/IES comparison incomplete.

Select Electrical Logo
Since 1988

Select Electrical Ltd. © Copyright 1988-2025